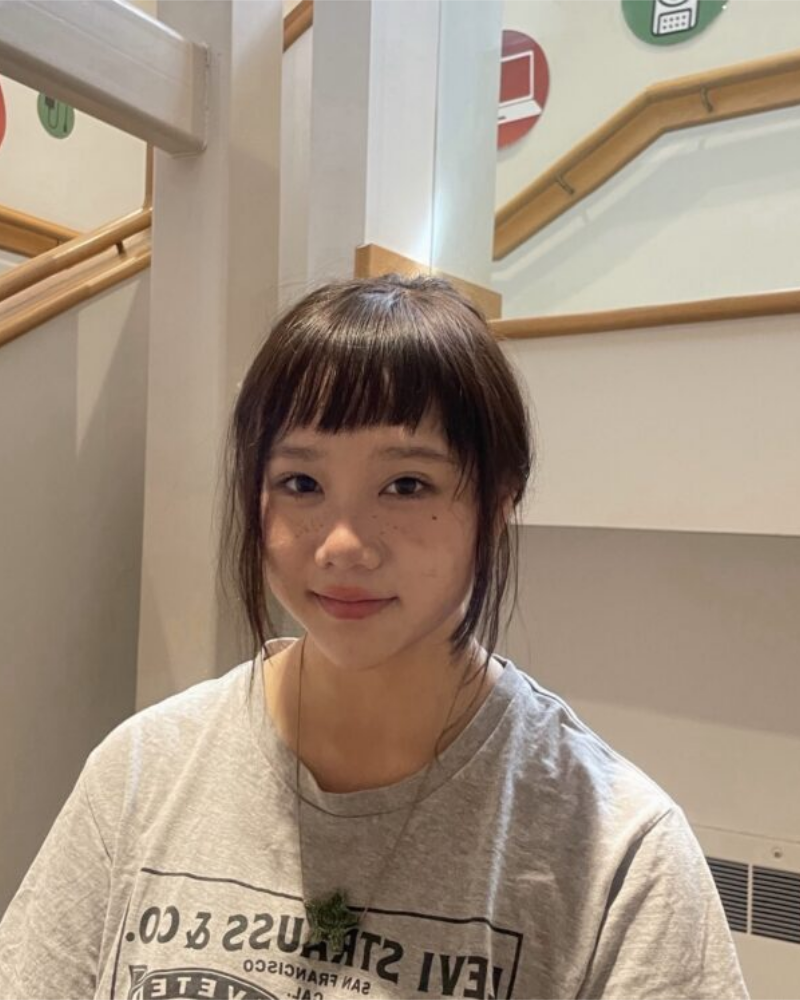
Khue Le

Geography & Data Science at Macalester College, graduating 2028. I turn drone, LiDAR and satellite pixels into maps that show how landscapes change, and where a bee can still get across town.

Portrait of Khue Le
Saint Paul, Minnesota

Mapping from above, checking on the ground.

I'm a junior double-majoring in Geography and Data Science. Most of my work starts in the air, with multispectral drone flights, LiDAR point clouds and decades of Landsat scenes, and ends with a question someone on the ground can act on: where to plant, what's been lost, what's still connected.

This year I'm a teaching assistant for two remote sensing courses, one at MIT Lincoln Laboratory's Beaver Works Summer Institute and one at Macalester, while running research on urban pollinator corridors and forest fragmentation in coastal Ecuador.

Studying
Geography + Data Science
School
Macalester College
Graduating
Spring 2028
Focus
Remote sensing, GIS, spatial modeling

Selected research

2026 · Macalester College & University of St. Thomas

Pollinator Path Corridor

A solitary bee forages only 100 to 200 meters from her nest. Between Macalester and St. Thomas, that's a lot of roof, road and lawn. I built a connectivity model from drone imagery, LiDAR and field surveys to find where bees can move today, and where one new garden would matter most.

  • Multispectral drone
  • NDVI
  • LiDAR canopy height
  • Resistance surfaces
  • Least-cost paths
  • Dijkstra
  • Field validation
0%of the corridor has moderate to very high foraging suitability
0%is high or very high, so there's real room to improve
0×costlier to cross between campuses than any link within one
0 kmbest bee route between the two campuses

How the model was built

  1. Drone imagery to NDVI. Multispectral flights over the corridor, converted to vegetation greenness as a proxy for flowers.
  2. LiDAR to canopy height. Surface model minus terrain model, with the 0.5 to 3 m flowering layer scored highest.
  3. Foraging suitability. Weighted overlay: 60% NDVI, 40% canopy height, resampled to 1 m.
  4. Resistance surface. The cost for a bee to cross each cell, with height-graded building barriers.
  5. Least-cost network. Dijkstra cost-distance and optimal paths linking 14 pollinator gardens.
  6. Field check. Compared with 197 surveyed yards: higher-rated yards scored higher on the map (Spearman ρ = +0.327, p < 0.001).
Research poster, 2026. Open it full screen, then scroll, pinch or double-click to read the details.

Watch the bee move

Bee Dijkstra Flood. Cumulative movement cost spreading outward from a garden near St. Thomas. High-cost links light up as pinch points. Open on YouTube
Bee Best Path. A virtual bee flying the single lowest-cost route between the two campuses across the resistance surface. Open on YouTube

What it means: the gap between campuses is the biggest barrier, back yards beat front yards (higher in 58% of 177 parcels), and sunny spots in already-suitable yards are the best places to plant next.

View code on GitHub

Advanced Remote Sensing · Coastal Ecuador · 1995 to 2024

Pacoche Land Cover & Vegetation Change

Twenty-five years of Landsat, six classified land-cover maps, one question: where has the forest around Pacoche held on, where has it gone, and where does it keep flickering back and forth?

  • Google Earth Engine
  • Landsat 5 & 8
  • QA_PIXEL cloud masking
  • NDVI & anomalies
  • Trajectory mapping
  • Change detection
Forest cover, 1995 → 2020, exported from Earth Engine.

Six dates, stacked and summed

Each classified map becomes a forest / non-forest layer. Stack all six, add them up, and every pixel gets a score from 0 to 6: the number of dates it was forest.

  • 0 never forest
  • 1–5 shifting forest
  • 6 forest every date

Greenness over time

NDVI = (NIR − Red) / (NIR + Red)

Cloud-free Landsat composites for 1994–95, 1998–99 and 2023–24, with sensor-specific bands for Landsat 5 and 8, split into northern and southern study areas.

Above or below normal

Anomaly = pixel NDVI − regional mean

An anomaly surface flags where vegetation is healthier or weaker than its surroundings, so historic and recent imagery can be compared fairly.

Built land, same lens

The same six-date trajectory workflow, run on the developed class, shows where settlement has been persistent and where it's new.

View code on GitHub

Experience

  1. Jul 2026 – now

    Teaching Assistant, Remote Sensing of the Environment

    Macalester College, Department of Geography · Saint Paul, MN

    • Coach students through satellite-image labs in ERDAS IMAGINE, ArcGIS Pro and Google Earth Engine.
    • Grade labs with technical feedback on spectral analysis and raster workflows.
    • Prep, test-fly and troubleshoot drones for field flight exercises.
    • Rewrite lab instructions, course materials and syllabus content.
  2. Jun – Sep 2026

    Teaching Assistant, Remote Sensing for Disaster Response

    MIT Lincoln Laboratory · Beaver Works Summer Institute · Remote

    • Guided students building Python remote sensing pipelines for disaster response.
    • Mentored machine learning and neural-network models for satellite classification and damage assessment.
    • Debugged Jupyter notebooks, geospatial libraries, coordinate systems and visualizations on the spot.
  3. Jan – Oct 2026

    Student Researcher, Pollinator Path Corridor

    Macalester College & University of St. Thomas · Saint Paul, MN

    • Built a GIS connectivity model linking two campuses for urban bees.
    • Fused multispectral drone imagery and LiDAR to map vegetation suitability.
    • Engineered resistance surfaces, garden networks and least-cost paths that expose corridor bottlenecks.
  4. Jan 2026 – now

    Research Assistant, Forest Fragmentation in Coastal Ecuador

    Macalester College · Saint Paul, MN

    • Track forest fragmentation and land-cover change with multi-temporal satellite imagery.
    • Build Earth Engine workflows for cloud masking, NDVI, change detection and forest trajectories.
    • Produce change maps of persistent forest, forest loss and shifting land cover.

Toolkit

GIS & remote sensing

  • ArcGIS Pro
  • QGIS
  • ERDAS IMAGINE
  • Google Earth Engine
  • LiDAR
  • NDVI
  • Land-cover classification
  • Change detection
  • Drone mapping

Programming & data

  • Python
  • R
  • JavaScript
  • GeoPandas
  • Rasterio
  • NumPy
  • Matplotlib
  • Statistical analysis
  • Spatial data analysis

Geospatial methods

  • Raster & vector analysis
  • Least-cost path modeling
  • Resistance surfaces
  • Spatial network analysis
  • Image classification
  • Multi-temporal analysis

Have a landscape question?
Let's map it.

Open to research positions, internships and GIS or remote sensing projects.

Pollinator research poster, full resolution
Loading full resolution…
100% Open image